CMU ECE · Looking for a Summer 2027 internship
Samuel Anes
Robotics, controls, systems, and software
On Carnegie Mellon Racing’s driverless team I lead two systems: the regenerative braking strategy, and the Delaunay edge selection that turns perceived cone positions into the path the car follows. My rebuild of that selection removed the planner’s mis-planned frames in replay and extended its usable lookahead by 54%. Before CMU I led FTC software for four seasons and shipped a real-time multiplayer game to 1,000+ users.
Carnegie Mellon University, B.S. Electrical and Computer Engineering, Graduating May 2030.
Relevant Coursework
- Intro to Electrical and Computer Engineering
- Calculus in Three Dimensions
- Concepts of Mathematics
Programming
Python · Java · C · C++ · SQL · JavaScript · HTML · CSS · Svelte
Software & Tools
GitHub · Claude Code · ROS 2 · Verilog · Linux · Android Studio · Onshape
Hardware
Arduino · 3D Printers · CNC Machines · Multimeter · Oscilloscope
Extracurriculars
Eagle Scout · FIRST Dean's List Semi-Finalist · FCC Amateur Extra · World Cube Association Competitor
Engineering Experience
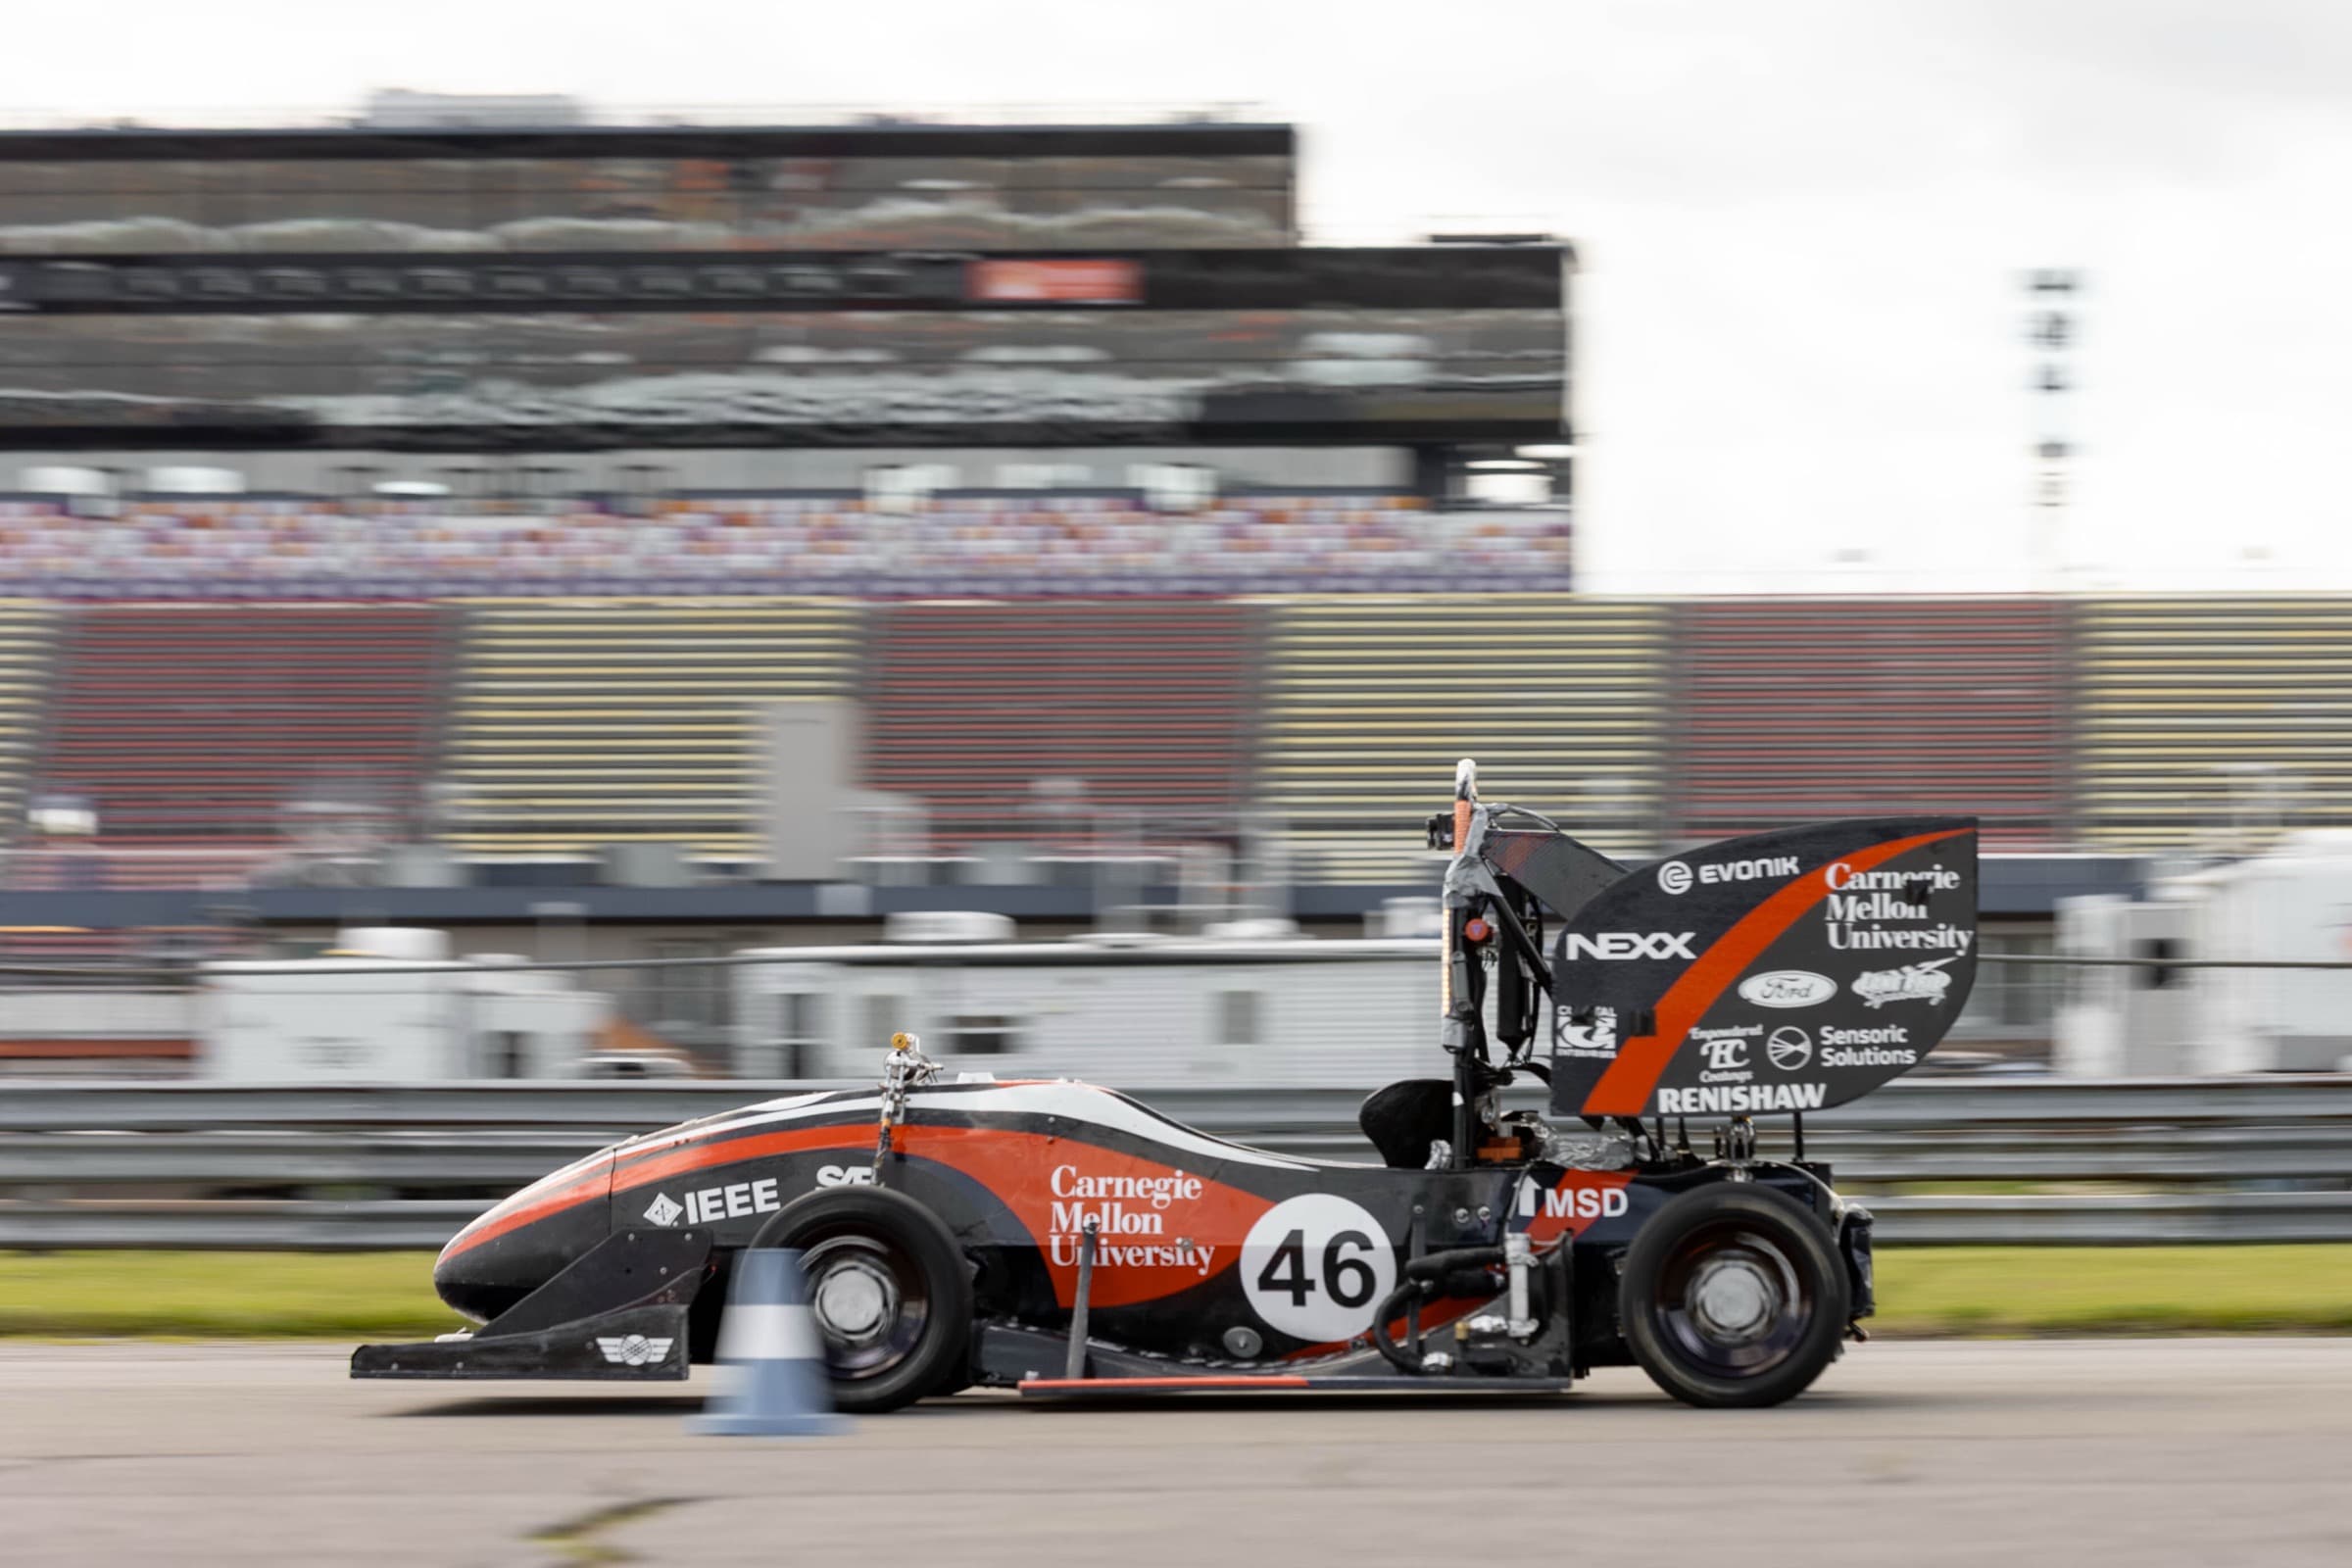
Featured · Driverless Controls and Path Planning
Carnegie Mellon Racing
One-pedal regenerative braking, the vehicle dynamics work behind it, and robust Delaunay edge selection for the driverless path planner. Three write-ups.
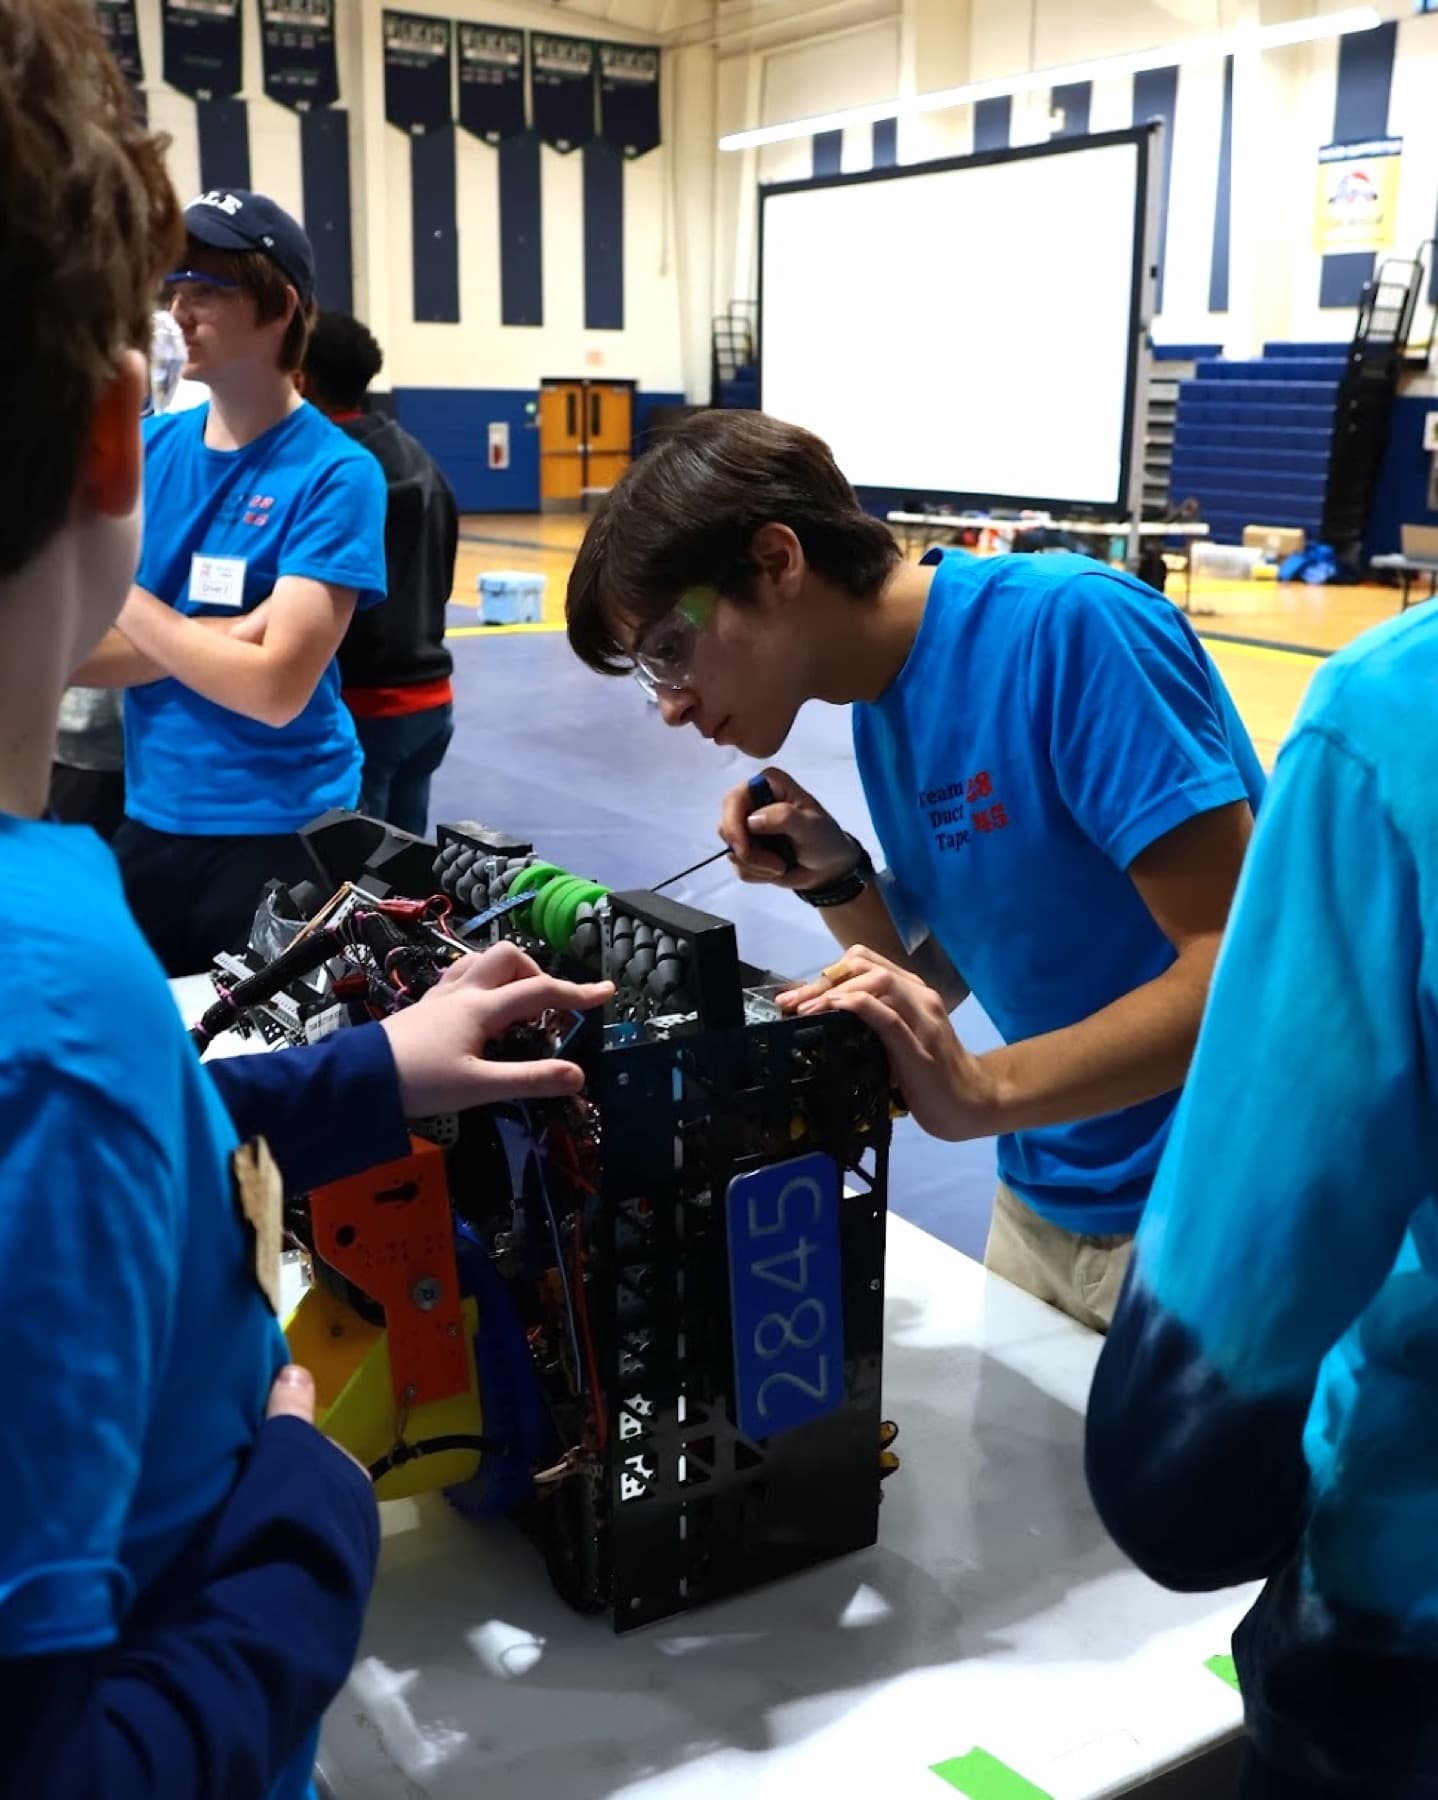
FIRST Tech Challenge Robotics
Parallel computing, odometry + IMU + computer vision sensor fusion, CAD turret design, and a data-driven game element launcher. Three-time winning alliance · 1st Place Inspire Award, 2026.
See the work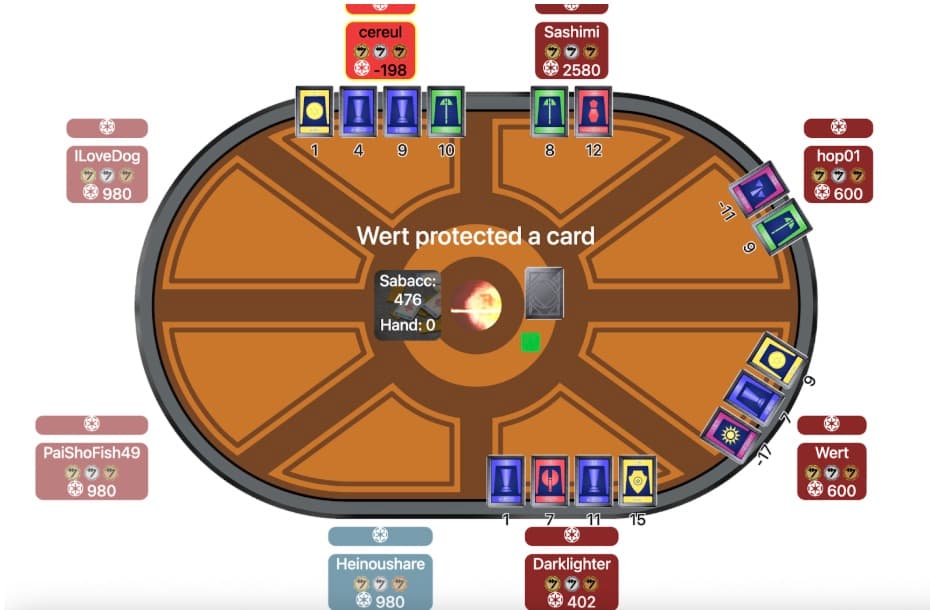
Sabacc Multiplayer Web Application
Founded and led a global project development team. Object-oriented backend, SQLite ↔ Postgres migrations, still actively serving users.
See the work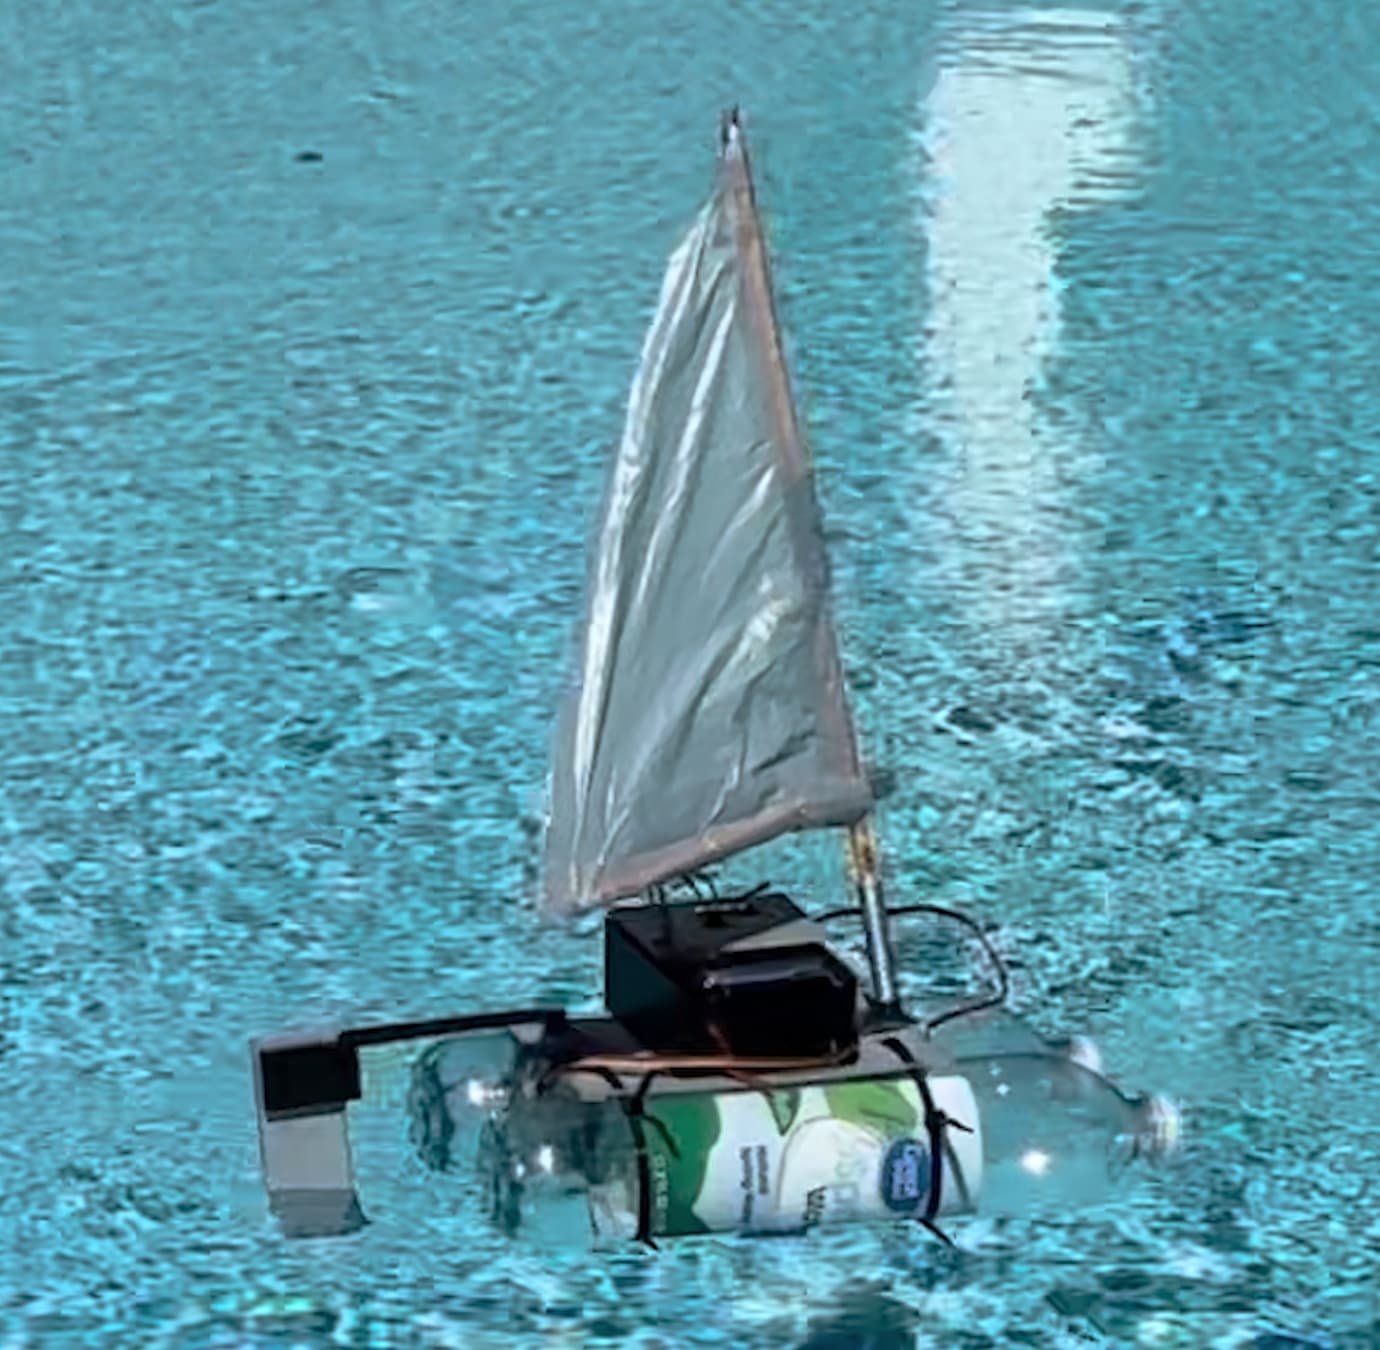
Embedded Projects
A remote-control sailboat with XBee radios and a hand-soldered adapter board, and two generations of a speedcubing timer, from an ultrasonic sensor to calibrated capacitive touch pads.
See the work