FIRST Tech Challenge · Team 2845, Team Duct Tape
Robot Autonomy and Controls
Over four seasons I went from a new programmer to leading my team’s software to becoming Team Captain. These are four problems that shaped the robot’s code, and how I solved each one.
2022–2026 · Tampa, FL · FIRST Dean’s List Semi-Finalist
Java · Android Studio · OpenCV · Limelight · goBILDA Pinpoint · FTC Dashboard
An FTC match opens with 30 seconds of autonomous, where the robot runs entirely on its own code, followed by two minutes of driver control. The game changes every year, but the software problems don’t: the robot has to know where it is, see what’s around it, and do several things at once. I wrote most of the robot code in the seasons below, and I kept running into the same pattern: the obvious approach had a flaw, so I built something that got around it.
Roles
Team Captain
2024 – 2026
Ran the team alongside writing its software: season planning, design reviews, and structuring the codebase so newer members had somewhere to start.
Software Lead
2022 – 2024
Owned the robot code. Rebuilt it around a command framework, then wrote the localization, PID navigation and vision pipelines on top of it.
Write-Ups
2025–26 Season
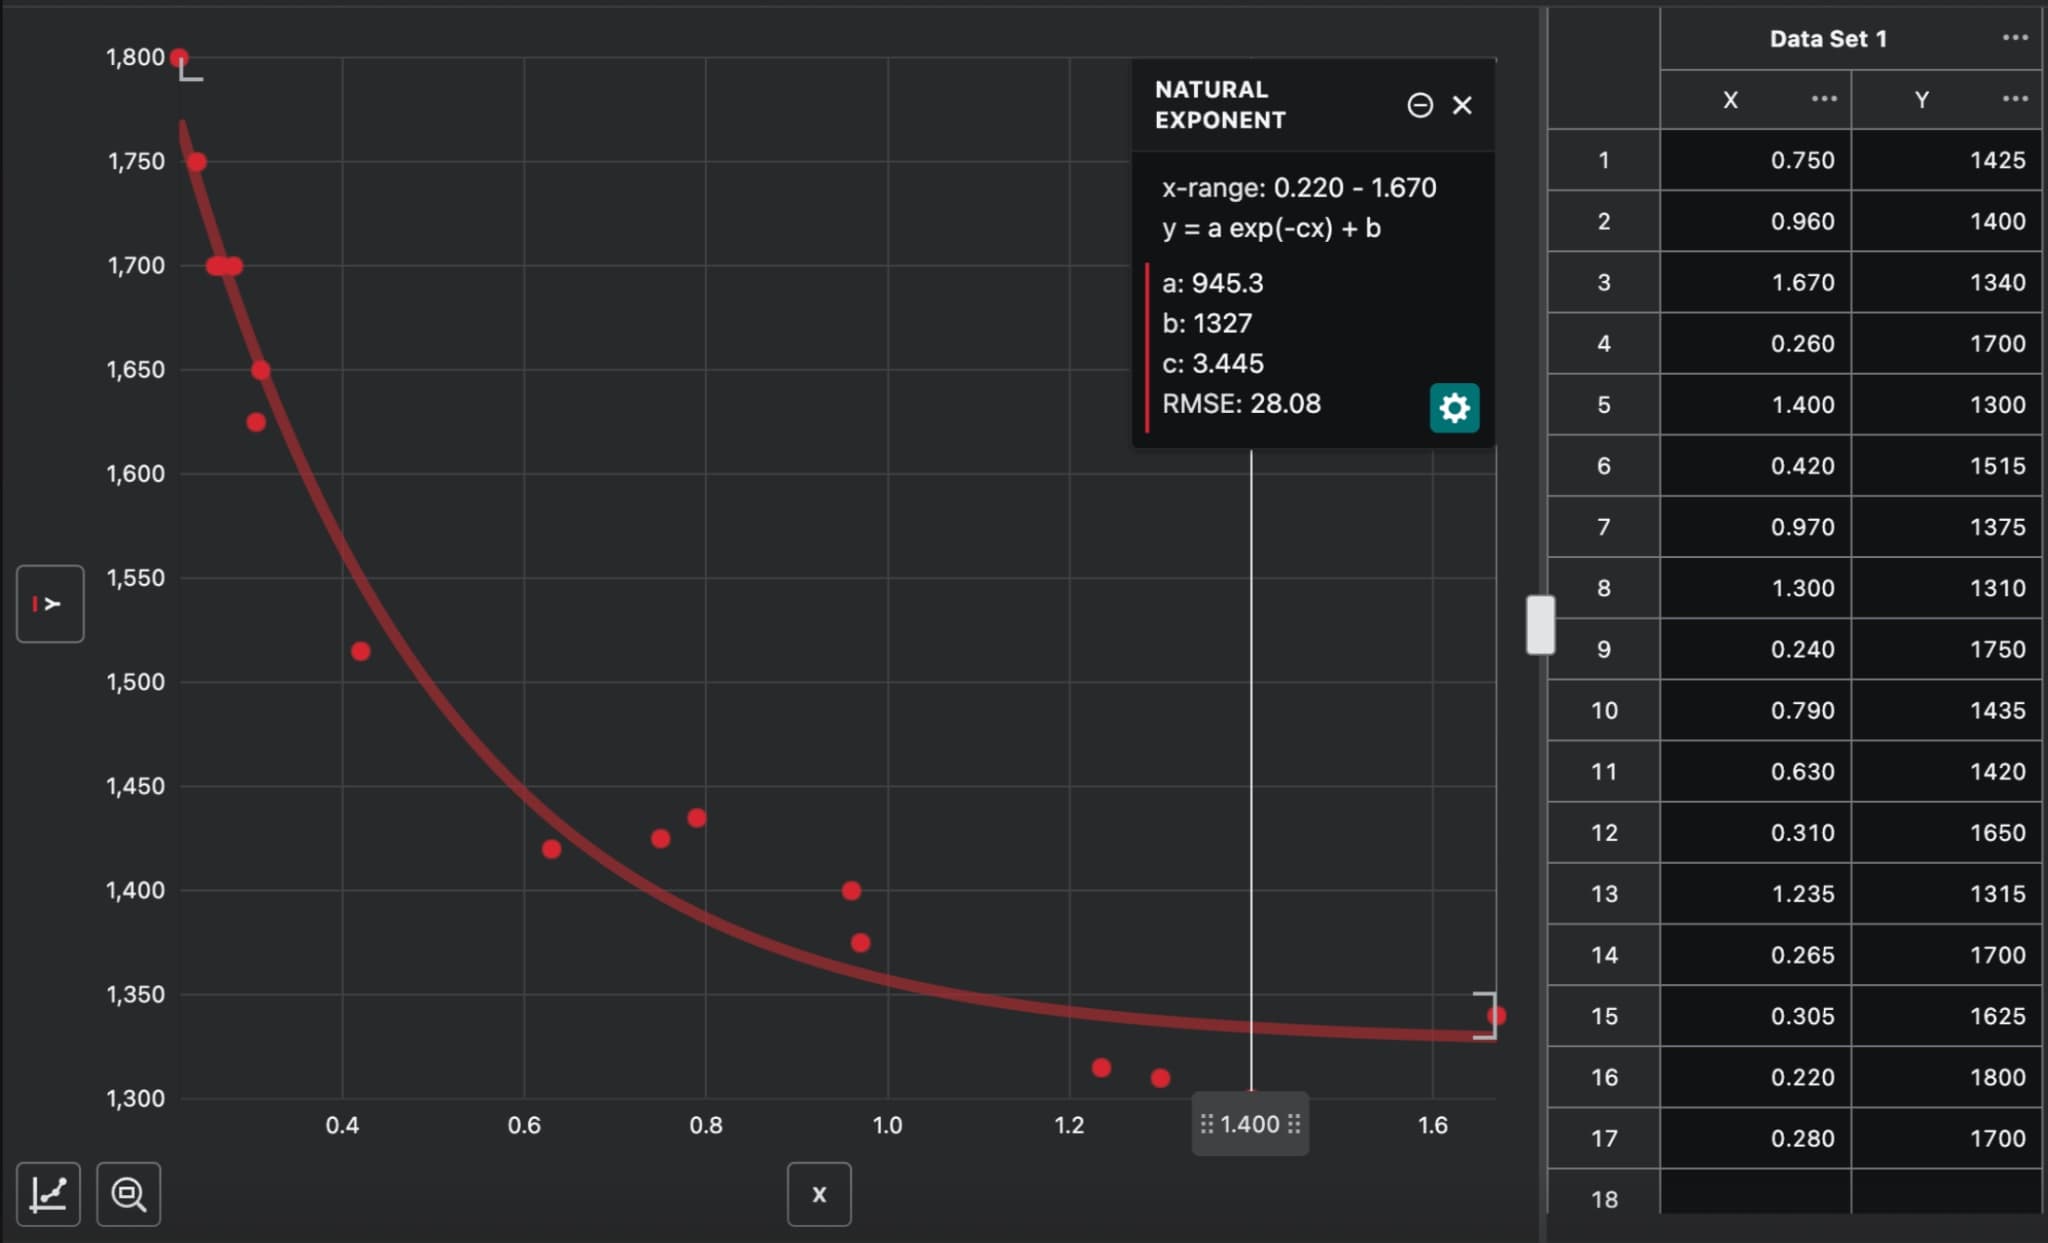
Turret Aiming and Launch Control
Aiming by turning the robot fell apart under defense. A camera-fitted launch model worked until the robot moved, so the final version aims from odometry and predicts where the robot will be when the ball lands.
- Java
- Limelight
- Curve Fitting
- Motion Prediction
2023–26 Seasons
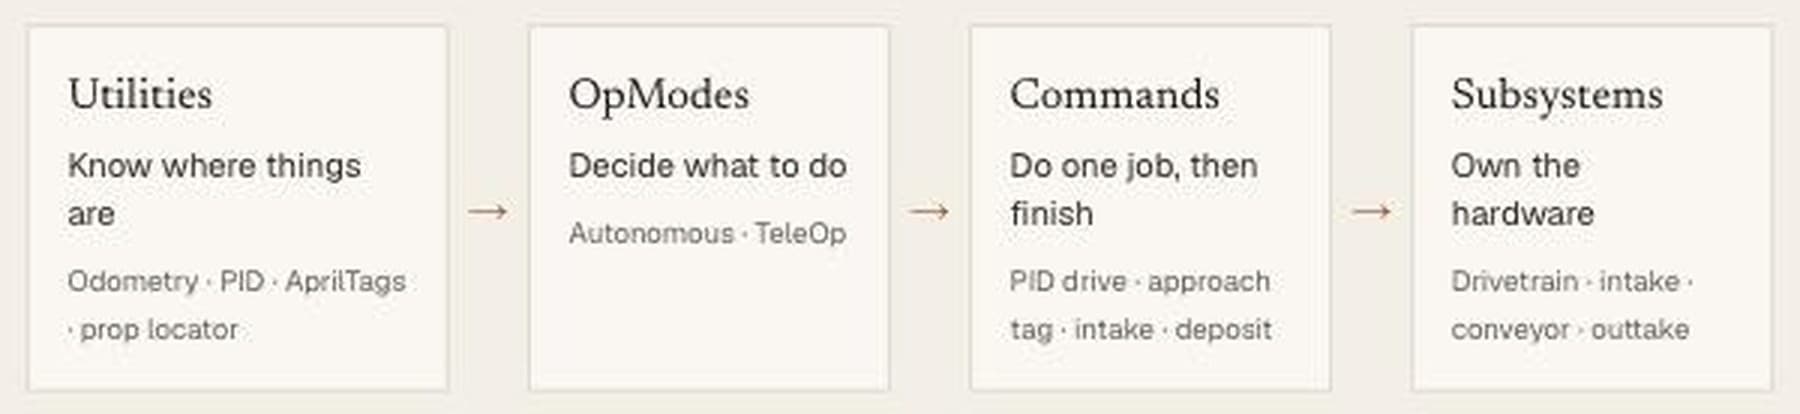
Concurrent Subsystem Control
A robot that drives, stops, intakes, stops, then scores wastes most of its 30 seconds. Four module types let subsystems run side by side, and a single I/O loop kept them from fighting over the hardware.
- Java
- Android Studio
- Multithreading
- Software Architecture
2023–24 Season
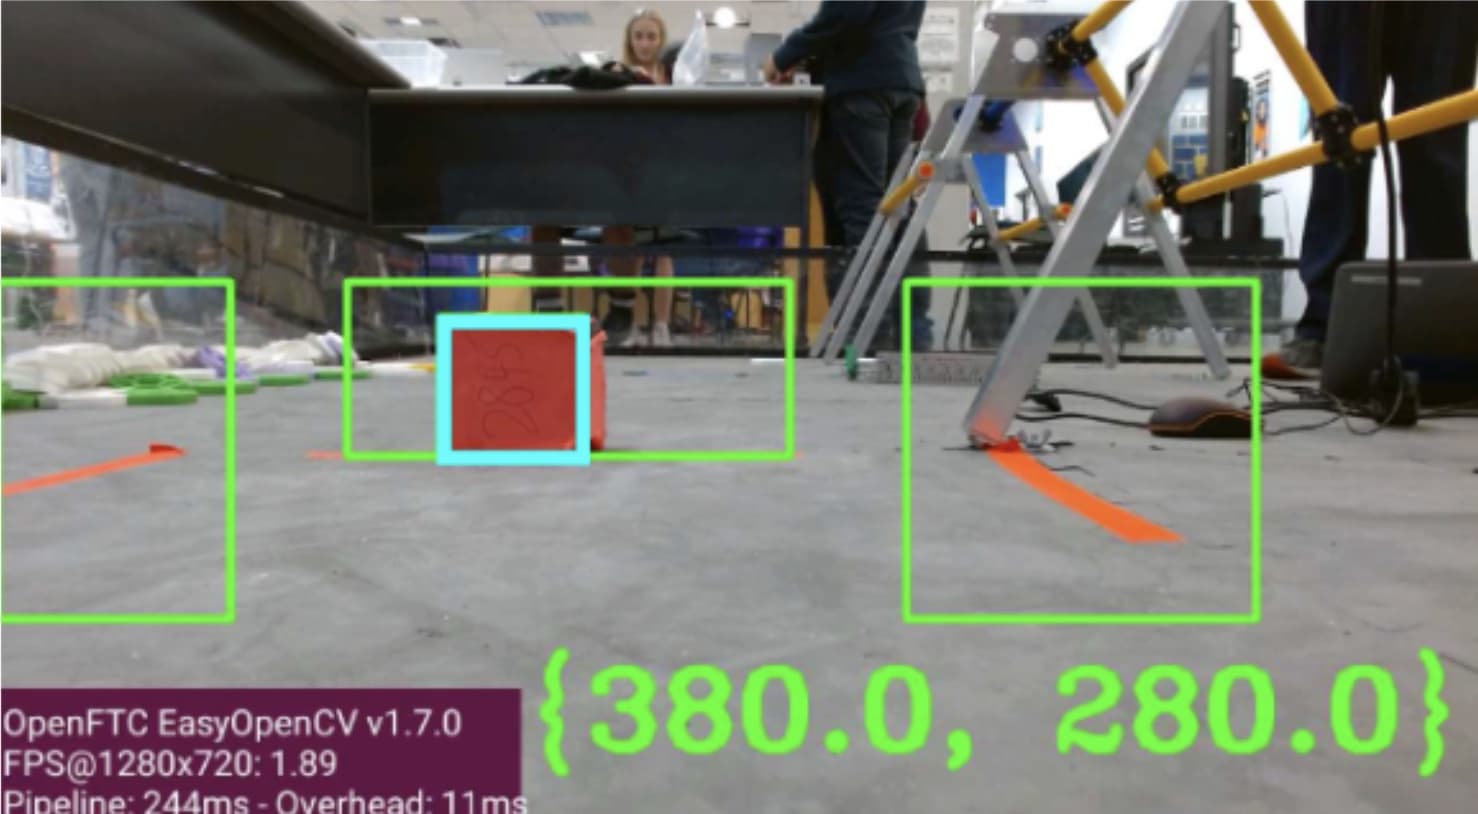
Computer Vision Pipelines
Finding a red or blue team prop in a gym full of red and blue, under lighting that changes venue to venue. Part of the answer was designing the prop as a cube before writing any code.
- Java
- OpenCV
- HSV Segmentation
- AprilTags
2023–24 Season
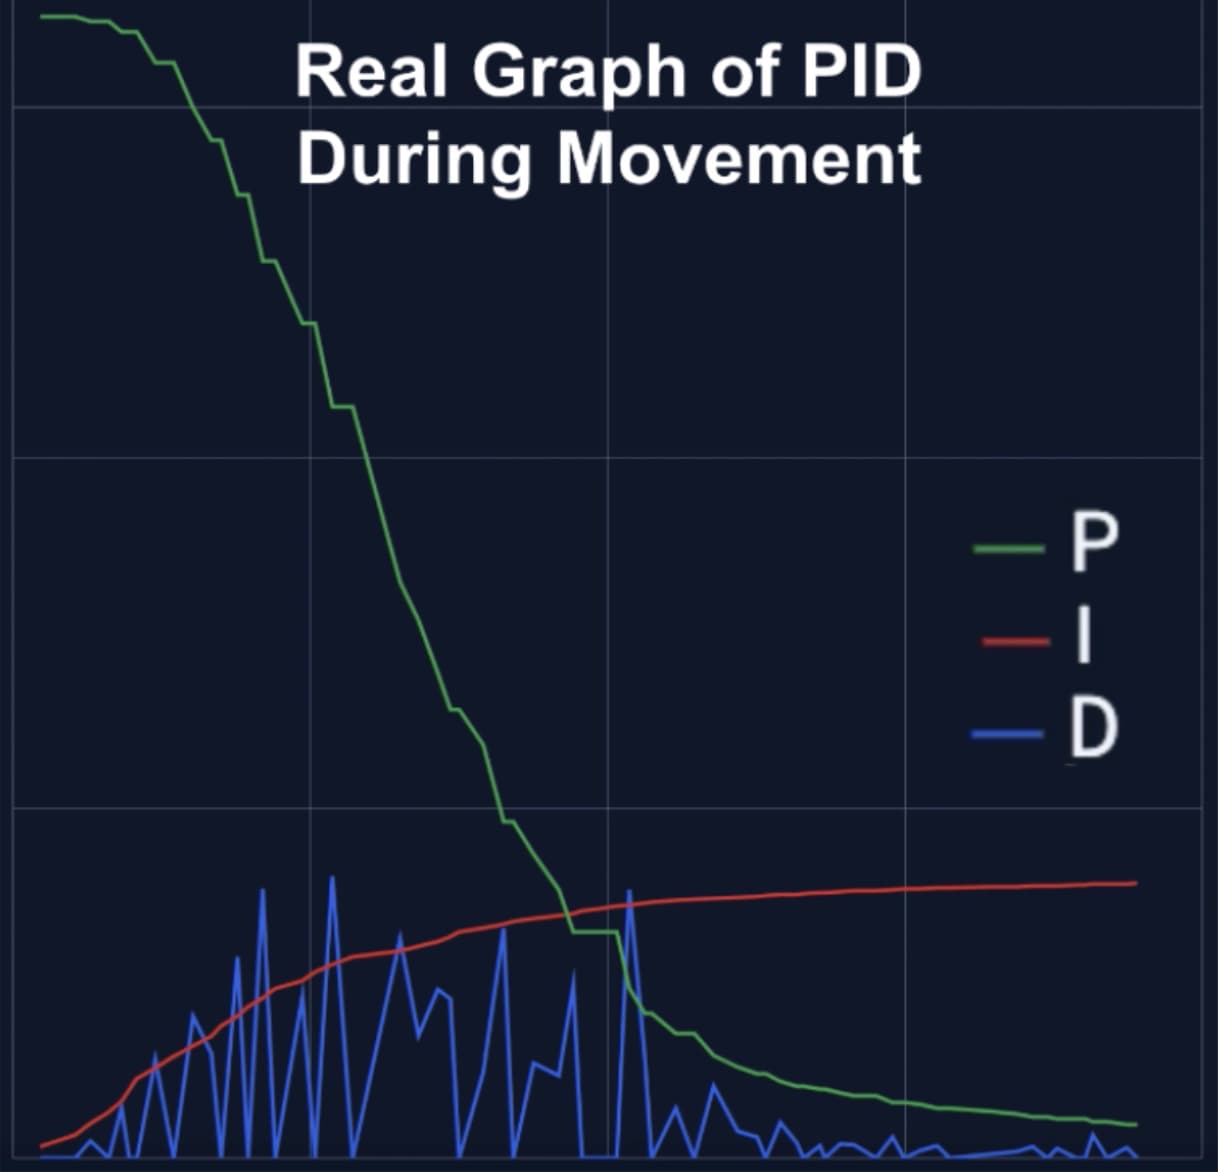
Localization and Navigation
Two-wheel odometry is accurate until the robot drives and turns at once; three-wheel drifts instead. I used both, with the IMU correcting the wheels, feeding a PID point-to-point navigator.
- Java
- Odometry
- Sensor Fusion
- PID Control
Results
- 2025–26R.O.B.O.T. League Inspire Award, 1st Place · Winning Alliance Partner · Florida State Championship
- 2024–25R.O.B.O.T. League Winning Alliance Captain · Florida State Championship
- 2023–24R.O.B.O.T. League Winning Alliance Captain · Florida State Championship
- 2022–23Control Award · Florida State Championship
2026 Design Video
Five minutes on the 2025–26 robot: the turret and its custom bearing, aiming, and how the code was organized so more teammates could work in it. I recorded it for a scholarship application, which is why it ends by mentioning WPI.